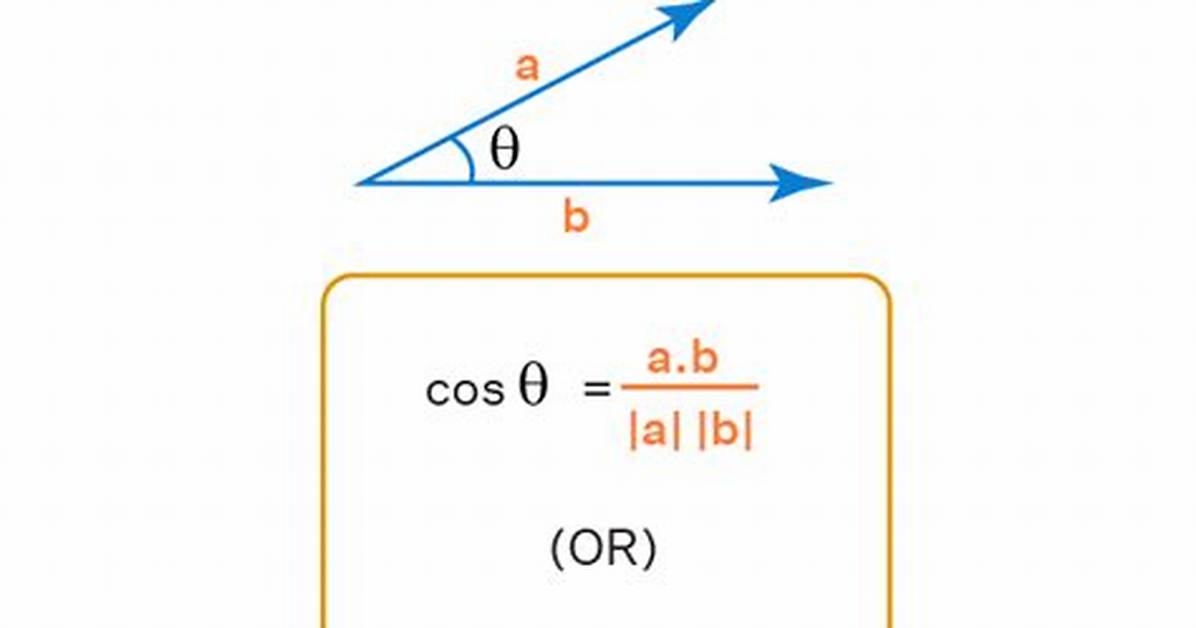
on this link I found the following formula:
signed_angle = atan2(b.y,b.x) - atan2(a.y,a.x)
or I can rewrite it as:
atan2(y, x) = atan(y / x)

vectors:
a = {x1, y1}
b = {x2, y2}

signed_angle = atan(y2 / x2) - atan(y1 / x1)
And it doesn't work properly for example when:
a = {-1, 0} and b = {1, 0}
Additionally I know a direction from first angle to a second one (clockwise or counterclockwise) but I don't know how to apply it to a first formula.
How to solve this issue?
2 Answers
My current solution:
angleAC = ... (angle of vector A with Ox)
angleBC = ... (angle of vector B with Ox)
dangle = (angleBC - angleAC) / n (n is a number enough to split a big angle to oblique angles)
if (dangle > 0 and clockwise) or (dangle < 0 and counterclockwise) then check angleAC and angleBC. If they are less than 0 then add 2 * Pi to them.
This action looks strange but it really allows to get angle from A to B according to clockwise/counterclockwise direction
I have dealt with the same problem.
Let us say that you have the vectors u = (u1, u2), v = (v1, v2) in the plane. What would be a good definition of a signed angle between the vectors u and v? One possible definition is to define it by the rotation angle that applied to vector u results in a vector with same direction and sense of v.
For example, if u = (1, 1) and v = (-1, 1), then the angle theta(u, v) would be + pi/2 (90 degrees), since if rotating u counterclockwise 90 degrees you get v. Observe that theta(v,u) is -pi/2, since you need to rotate v 90 degrees clockwise to obtain u.
Observe also that you could also rotate u by -3*pi/2 (-270 degrees) to get v. So, in order to make the definition unique, you should pick up the angle that lies in (-pi, pi]. Observe that for the vectors u = c(1,1) and v = (-1,-1), the angle could be +pi (+180) or -pi (-180), so you need to choose one, e.g., +pi.
In general, we have the following properties of the theta function:
- theta(u,v) = -theta(v,u)
- theta(-u, v) = theta(u,v) - pi
- theta(u,-v) = theta(u,v) - pi
One R script to implement that function using atan2 function is given below:
theta <- function(u, v) {
    # u, v: matrices of bivariate vectors with 2 columns
    u <- matrix(u, ncol = 2)
    v <- matrix(v, ncol = 2)
    if (nrow(u) != nrow(v)) stop("u and v must have the same number of
                                  rows")
    result <- as.numeric(atan2(v[,2], v[,1]) - atan2(u[,2], u[,1]))
    ind1 <- which(result > pi)
    ind2 <- which(result <= -pi)
    result[ind1] <- result[ind1] - 2*pi
    result[ind2] <- result[ind2] + 2*pi
    return(result)
} # end-function
I hope this helps,
Luis Ernesto

