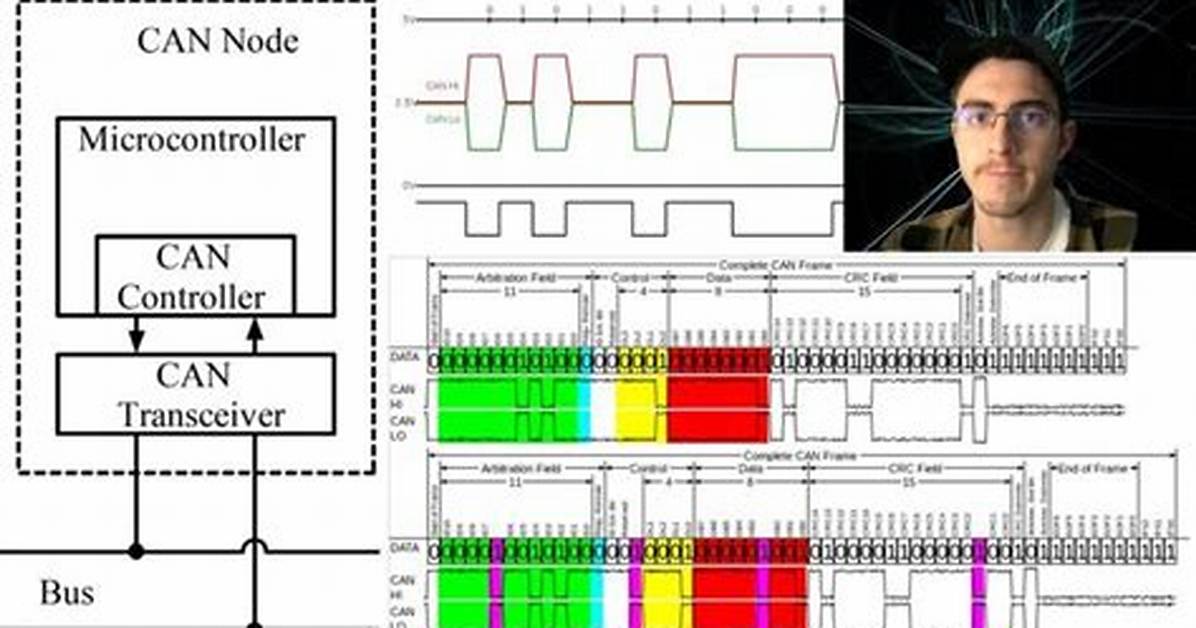
CAN protocol is a message-based protocol, not an address based protocol. This means that messages are not transmitted from one node to another node based on addresses. Embedded in the CAN message itself is the priority and the contents of the data being transmitted.
CAN protocol explanation?
The CAN communication protocol is a carrier-sense, multiple-access protocol with collision detection and arbitration on message priority (CSMA/CD+AMP). CSMA means that each node on a bus must wait for a prescribed period of inactivity before attempting to send a message.
CAN frame explained?
Basically, the Remote Frame is a Data Frame without the Data Field. Per definition a CAN data or remote frame has the following components: … Arbitration Field – Includes the message ID and RTR (Remote Transmission Request) bit, which distinguishes data and remote frames.

